➜~whoami

Nishanth
Rajkumar

  • Forward Deployed Engineer · Robotics
  • AMR Deployment
  • Robot Perception
  • Simulation
  • Systems Integration

I’m a systems engineer at Rockwell Automation, where I deploy fully autonomous industrial AMRs for material handling at Fortune 500 companies like GM and Nissan, on site from commissioning through production.

I also build robotic systems that connect mechanical design, controls, ROS, simulation, perception, and real-world deployment.

nishanth@lab: ~/profile.yaml
Portrait of Nishanth Rajkumar
1# profile.yaml
2role:Forward Deployed Engineer · Robotics
3at:Systems Engineer @ Rockwell Automation
4ships:autonomous industrial AMRs, on site
5customers:[GM, Nissan, Fortune 500]
6focus:[physical-ai, perception, sim-to-real]
7stack:[ros2, isaac-sim, gazebo, genesis, solidworks]

01// overview

Projects overview

Autonomy, controls, perception, data and validation, across real hardware and simulation.

amr-systems/AMR SystemsAutonomous navigation
controls/Control SystemsCascaded control
perception/PerceptionFine-tuning SOTA models
systems/System EngineeringArchitecture design
datasets/Dataset CollectionQuery-adaptive VLA fine-tuning for precise manipulation
programming/Robot ProgrammingFP programming and calibration
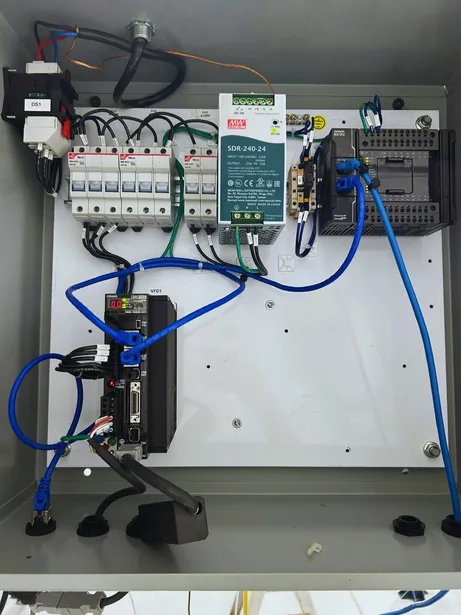
Modular electrical safety panel
safety/Safety SystemsModular safety system
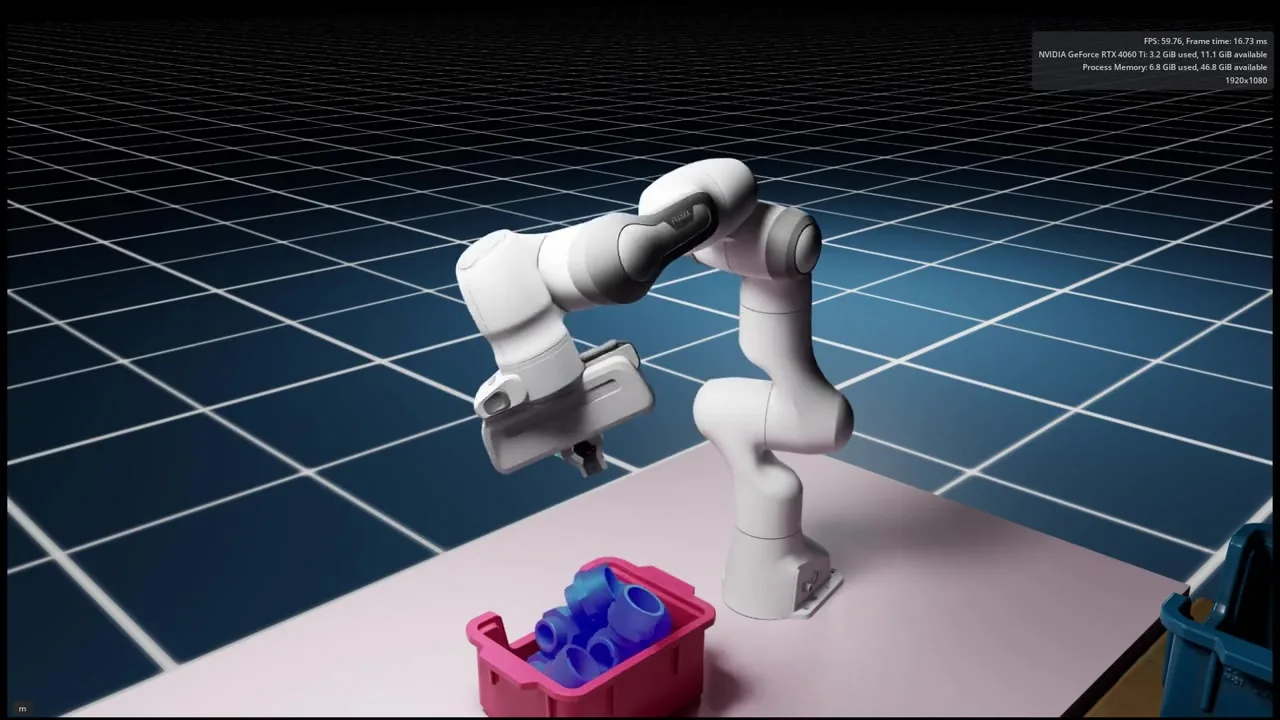
Franka arm in Isaac Sim picking from a bin
sim/Digital Twin ValidationIsaac Sim zero-shot bin-picking validation

02// specialties

Core specialties

From perception models to commissioning on the factory floor, these are the five areas I work across.

  • Robot Perception & Physical AI

    Data collection, perception pipelines, robot re-targeting, sim-to-real workflows, hardware-software setup, and fine-tuning SOTA models for robotic tasks.

    0x01
  • ROS 2, Simulation & Digital Validation

    I build and test robot behavior using ROS 2, Isaac Sim, Gazebo or Genesis simulation workflows, and virtual validation before or alongside hardware testing.

    0x02
  • Robotic Systems Integration

    I connect robot software, sensors, controls, hardware, and workflows into complete systems that work reliably outside the lab.

    0x03
  • Industrial AMR Deployment & Debugging

    I commission, test, troubleshoot, and optimize AMR systems in customer environments, including workflow validation, recovery planning, and field issue investigation.

    0x04
  • Mechanical Design, Controls & Manufacturing

    I design practical robotic mechanisms with CAD, DFM, actuator selection, control thinking, prototyping, and manufacturing awareness.

    0x05

03// tier-1 · forward deployed

Forward-deployed robotics

On site with the customer: industrial AMR fleets taken from commissioning to production support in live plants.

OTTO Motors by Rockwell Automation

AMR systems integration, commissioning → production

Hands-on systems integration experience delivering OTTO Motors AMR deployments from commissioning through production support.

  • Commissioned AMR fleets (>50) in live manufacturing environments
  • Integrated robot workflows with PLCs, OPC UA, and industrial middleware
  • Designed and validated missions, interlocks, docking, and material-flow logic
  • Analyzed fleet traffic, cycle times, utilization, and production bottlenecks
  • Diagnosed localization, navigation, hardware, and system-integration issues
  • Supported production launches, acceptance testing, and customer training
  • Bridged robotics, controls, software, and manufacturing operations
General MotorsRockwell AutomationOTTO Motors
Watch OTTO AMRs at work on YouTube
Close-up of an OTTO autonomous mobile robot
>50AMR fleets commissioned

04// tier-2 · research

Flagship research projects

Robot learning: teleoperation data generation, policy routing for long-horizon tasks, and geometry-aware VLAs.

01

Quest2Skill

cross-embodiment retargeting · synthetic data generation

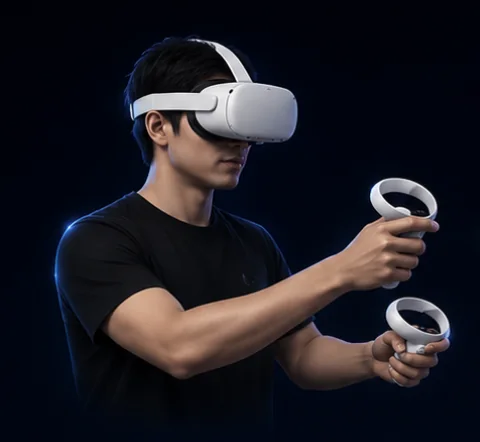
Capture human manipulation trajectories, retarget the end-effector motion to different robot arms, and generate synthetic demonstrations in simulation.

Case study
Operator wearing a Meta Quest headset holding both controllers
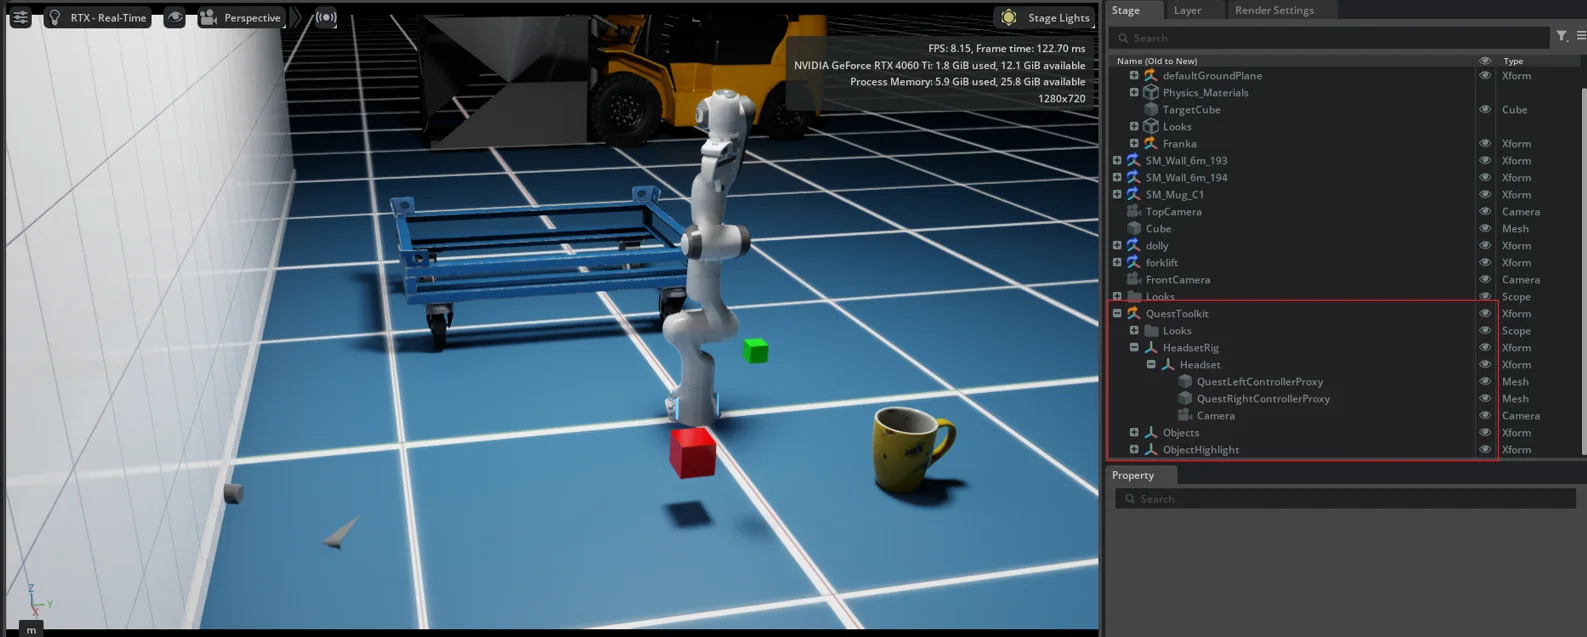
custom toolkit, drops into any env to manipulate objects
digital twin: isaac sim
Isaac Sim scene with a Franka arm, a red cube and a mug
log end-effector trajectory at every timestep of an episode
retarget via Lula IK + RMPflow
  • xr-teleop
  • robot-retargeting
  • dataset-gen
  • isaac-sim
02

Lightweight Visual Router

adaptive query-routing for long-horizon tasks

Uses visual feedback to track task progress and select focused short-horizon instructions for a fine-tuned robot policy, improving execution and recovery across multi-stage manipulation tasks.

Case study
TaskObserveRouteAct ↺ feedback
  • vla-pi0.5
  • query-router
  • state-estimation
  • error-recovery
03

Geometry-Aware VLA with Structured Action Generation

π0 + learned depth & segmentation · B-spline trajectory prediction

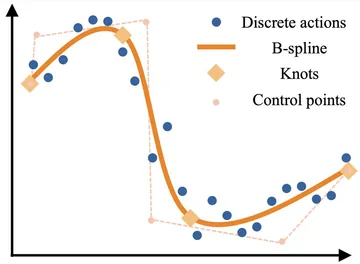
Extends π0’s SigLIP vision encoder with learned depth and segmentation features for richer spatial understanding, fused into the policy through cross-attention. B-spline control points (inspired by B-Spline policy) are predicted to generate smoother, more structured robot trajectories.

coming soon
Plot comparing discrete actions with a fitted B-spline, its knots and control points
  • geometry-aware-perception
  • depth-fusion
  • segmentation-features
  • b-spline-actions
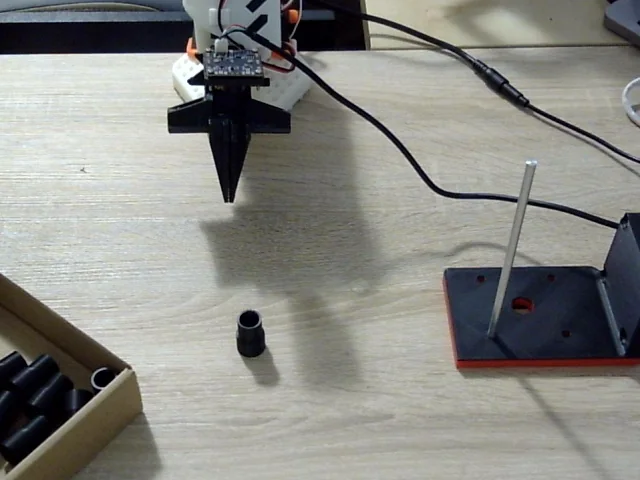
Peg-insertion setup with the gripper above a peg on its stand

05// tier-3 · engineering

Flagship engineering projects

Robots and machines built end to end: CAD, fabrication, electronics, controls and software.

01

Dandebot

autonomous mobile robotics platform

A mobile robotics platform built to explore autonomous navigation, perception, and real-world robot control. It integrates sensing, localization, mapping, and motion control into a compact end-to-end robotics system.

  • Built from the ground up: mechanical, electrical, and software integration
  • Autonomous navigation: mapping, localization, path planning, and obstacle avoidance
  • Real-world experimentation: testing robotics algorithms outside simulation
  • autonomous-nav
  • weed-segmentation
  • low-level-control
  • diff-drive
Case study
02

Franka Bin Picking

zero-shot perception → 6-DoF grasping

A robotic bin-picking pipeline for the Franka arm combining perception, 6-DoF pose estimation, and grasp generation to detect objects in clutter and execute reliable pick motions.

Foundation Stereo→CNOS zero-shot segmentation→6-DoF object pose→Grasp selection + motion planning→Franka pick execution
  • 6d-pose
  • instance-seg
  • grasp-gen
  • closed-loop
Case study
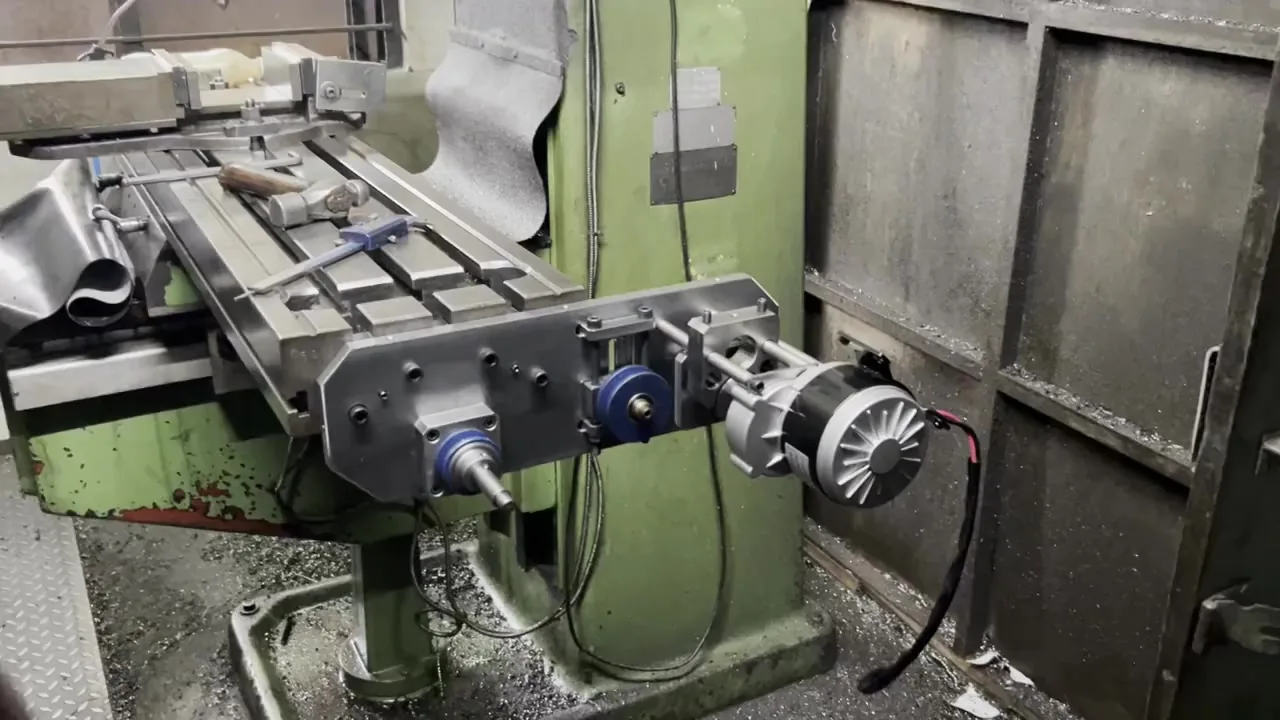
TorqueMate power feed mounted on a manual milling machine03

Torque Mate

low-cost milling machine power feed

A custom-built milling machine power feed designed as a practical, low-cost alternative to commercial systems. TorqueMate combines mechanical design, motor control, and custom electronics to automate table feed while keeping the system affordable and easy to retrofit.

$130build cost vs $400 commercial power feeds, about 3× cheaper
  • Custom mechanical design and fabrication, a modular fit for conventional milling machines
  • Motor drive and embedded control integration
  • Designed for retrofit on an existing manual mill
  • servo-drive
  • torque-regulation
  • precision-feed
  • load-adaptive
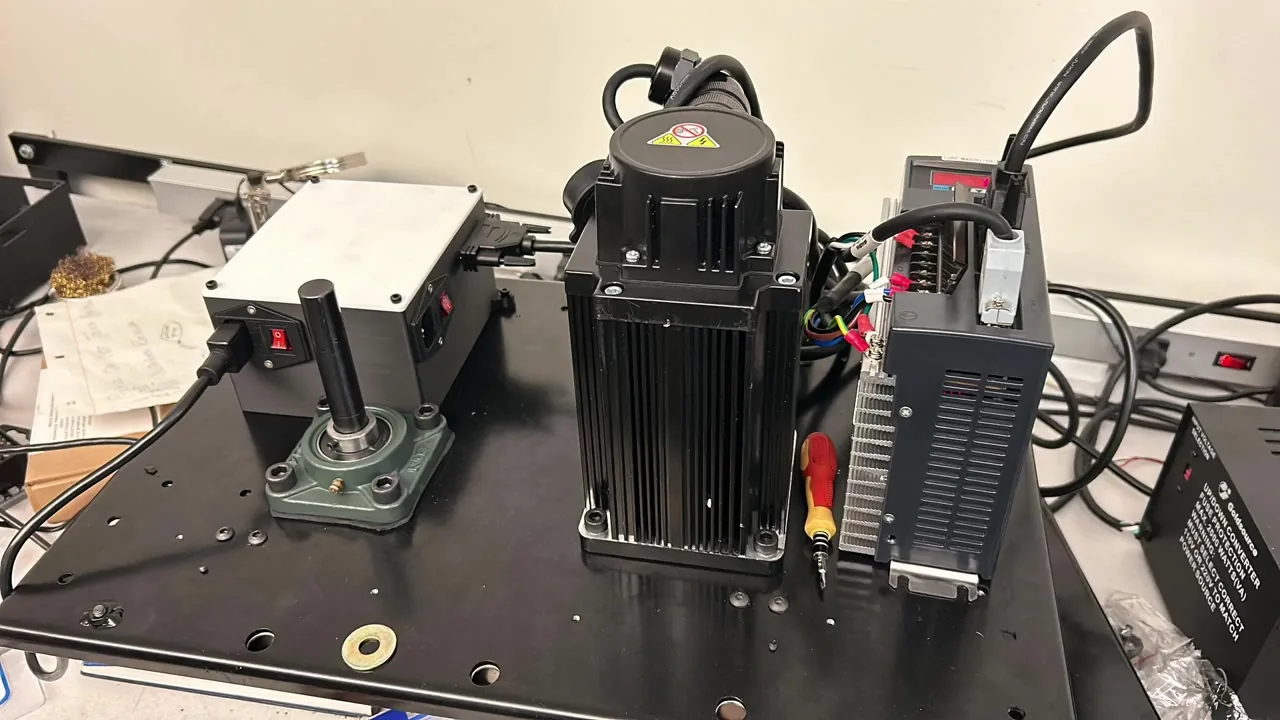
Primum Mobile drivetrain test rig with motor and driver04

Primum Mobile

high-speed rotor drivetrain

A custom drivetrain that provides the torque needed to spin a suspended rotor at high speed while keeping rotational motion stable.

  • Timing-pulley reduction drivetrain to increase available torque from the motor
  • Pulley ratio selected to balance rotor speed and torque requirements
  • Mechanical mounting and transmission components designed in SolidWorks and fabricated
  • Motor drive and embedded control integrated using Python/C++
  • Physical prototype built and tested for stable high-speed rotor operation
  • power-transmission
  • timing-belt
  • rotor-dynamics
  • torque-speed